Mobile Servicing System
Videos
The Mobile Servicing System is a robotic system on board the International Space Station. Launched to the ISS in 2001, it plays a key role in station assembly and maintenance; it moves equipment and s

Astronaut Stephen K. Robinson anchored to the end of the Canadarm2 during STS-114, 2005

Canadarm2 moves Rassvet to berth with the station on STS-132, 2010
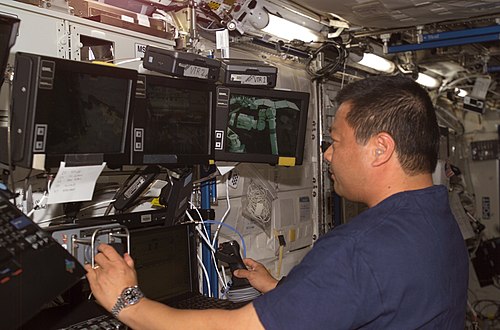
Astronaut Leroy Chiao controlling Canadarm2 from the Destiny lab

The exterior of the Canadarm is clad with Kevlar fabric, while the arm itself is made from titanium, pictured above Lake Balkhash.
Canadarm
Videos
Canadarm or Canadarm1 is a series of robotic arms that were used on the Space Shuttle orbiters to deploy, maneuver, and capture payloads. After the Space Shuttle Columbia disaster, the Canadarm was al
Mobile Servicing System
…SSRMS), Canadarm2 was launched on STS-100 in April 2001. This second generation arm is a larger, more advanced version of the Space Shuttle's original Canadarm. Canadarm2 is 17.6 m (58 ft) when fully extended and has seven motorized joints (an 'elbow' hinge in the middle, and three rotary joints at each of the…

Canadarm (right) during Space Shuttle mission STS-72

Life-size replica of the Canadarm at the Euro Space Center in Belgium

Story Musgrave, anchored on the end of the Canadarm, prepares to be elevated to the top of the Hubble Space Telescope during STS-61.

Peter J.K. Wisoff on the end of the arm, 1993